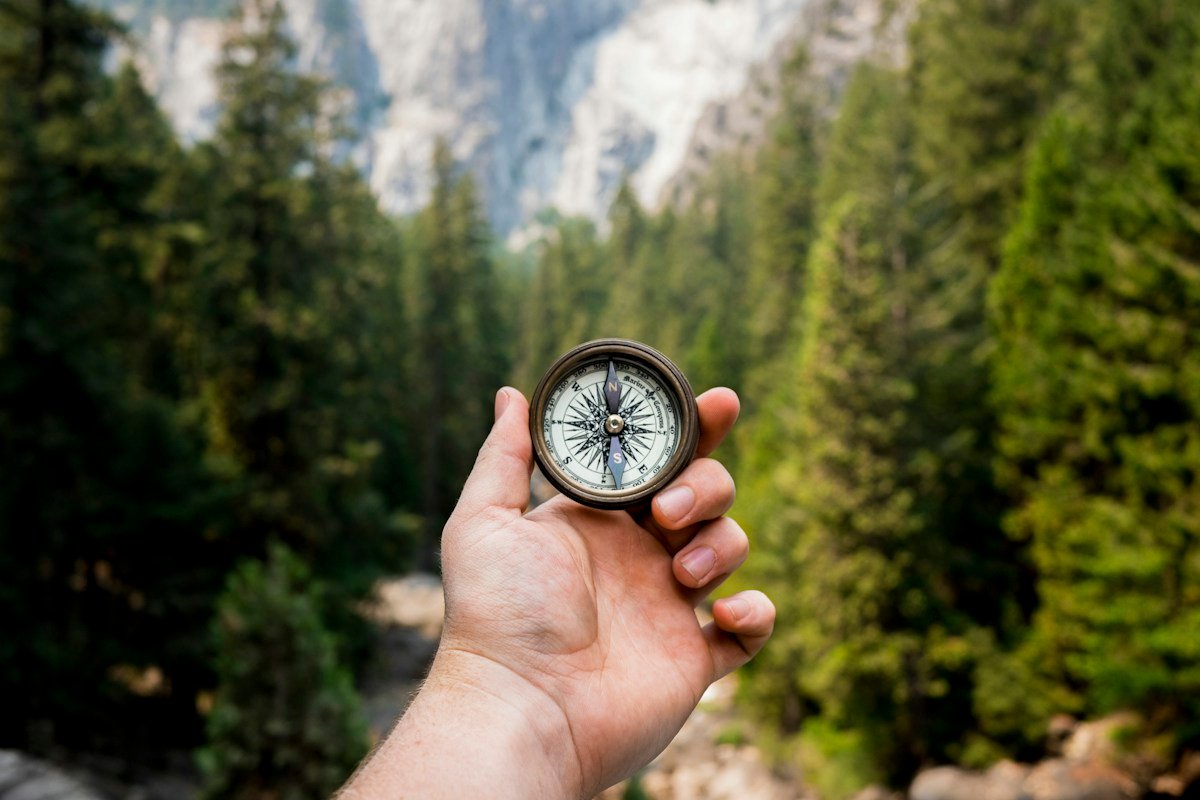

Modern wilderness exploration has become perilously dependent upon digital satellite navigation arrays, handheld Global Positioning System (GPS) receivers, and smartphone mapping applications. While satellite telemetry provides instantaneous coordinates under benign conditions, total electronic dependence establishes a catastrophic single point of failure in severe backcountry alpine environments. Rechargeable lithium battery chemistry degrades rapidly when ambient temperatures drop below freezing, sensitive electronic screens shatter during high-angle scree falls, dense cloud cover and steep glacial cirque walls attenuate satellite signals, and regional geomagnetic storms can blind digital receivers without warning. When digital hardware fails in remote wilderness, an expedition’s survival hinges upon the timeless, infallible science of analog topographic orienteering.
Analog alpine navigation transcends the mechanical act of following marked foot trails or staring at compass needles. It operates as an integrated cognitive discipline synthesizing three-dimensional terrain association, barometric altimetry tracking, celestial positioning geometry, and calculated dead reckoning. In glaciated alpine landscapes, pathless talus fields, and whiteout blizzards where visual landmarks vanish, a navigator must translate two-dimensional paper contour lines into a living mental terrain model, predicting contour elevation profiles, avalanche terrain traps, and impassable cliff bands miles ahead of physical arrival.
Executing reliable off-grid navigation through complex mountainous wilderness requires deep technical fluency in map projections, magnetic declination mathematical adjustments, resection geometry, and terrain-specific route-finding strategies. Mountaineers and wilderness expedition leaders must accurately calculate pacing ratios across varying slope gradients, establish precise catch features, and maintain continuous situational awareness under extreme physiological exhaustion. This technical manual provides an exhaustive navigational blueprint for planning, navigating, and surviving remote alpine expeditions entirely independent of satellite telemetry or electronic navigation aids.
Furthermore, mastering traditional orienteering fundamentally elevates the wilderness traveler’s psychological resilience and ecological connection to the landscape. Rather than experiencing the alpine wilderness through a six-inch illuminated glass screen, analog navigators develop acute observational sensitivity to geological strata, microclimatic wind drift, snowpack aspect transformations, and solar shadow vectors, transforming raw wilderness from an intimidating void into an intricately legible navigational tapestry.
Cartographic Foundations: Topographic Map Projections and Coordinate Grids
The foundation of all analog navigation begins with cartographic comprehension. A topographic map is a two-dimensional mathematical projection of three-dimensional terrestrial terrain, where physical relief, elevation changes, hydrography, and cultural features are transcribed through precise mathematical conventions. Commercial mountaineering expeditions utilize 1:24,000 scale United States Geological Survey (USGS) 7.5-minute quadrangles, or 1:25,000 scale European alpine cartography.
On a 1:24,000 scale quadrangle, one unit of measurement on the map represents exactly 24,000 identical units on the ground: one millimeter on paper translates to twenty-four meters of horizontal terrain, and approximately four centimeters equals one kilometer. Understanding scale resolution dictates navigational planning: while a 1:50,000 scale map provides wide regional context for multi-week expeditions, it lacks the fine spatial contour detail required to identify a five-meter impassable rock band or a hidden avalanche terrain trap during zero-visibility storms.
Grid systems provide the spatial reference framework for terrestrial coordinates. Topographic maps integrate the Universal Transverse Mercator (UTM) metric grid system alongside standard latitude and longitude degrees, minutes, and seconds. The UTM system projects the globe across sixty longitudinal zones, overlaying a uniform one-thousand-meter square metric grid across the landscape. The UTM grid simplifies wilderness navigation: distances between grid lines represent exactly one kilometer, allowing navigators to calculate horizontal distances and plot six-digit or eight-digit metric grid coordinates using clear plastic coordinate scales with millimeter accuracy.
Map durability is an essential operational consideration. Standard paper maps turn to pulp within hours of exposure to driving alpine rain, sleet, or sweat. Navigators must seal maps within waterproof flexible polyurethane map cases or print digital cartographic quadrangles directly onto synthetic waterproof polymer paper (such as Hop-Syn or Teslin) using water-resistant pigment inks, ensuring that vital contour details remain legible during sub-zero mountain storms.
Contour Line Interpretation and Three-Dimensional Terrain Modeling
Contour lines represent the core cartographic language of topographic maps. A contour line is an imaginary isoline connecting points of equal elevation above mean sea level. The vertical distance between adjacent contour lines, termed the contour interval (typically forty feet on USGS maps or ten to twenty meters on metric maps), remains constant across the entire quadrangle sheet, providing an exact mathematical representation of terrain steepness.
Interpreting contour morphology requires translating two-dimensional spatial patterns into three-dimensional terrain features. Closely packed contour lines indicate extreme vertical steepness, representing shear rock headwalls or technical alpine couloirs; widely spaced contour lines depict gentle valleys, high alpine plateaus, or broad glacial basins. Index contours, rendered as heavy, bold lines accompanied by explicit elevation numbers printed at regular intervals (typically every fifth line), provide immediate elevation anchors that prevent visual miscounting across complex cliffs.
Specific contour geometries correspond to universal landforms. V-shaped contour lines pointing upstream toward higher elevations represent water drainage channels, ravines, and active avalanche gullies; conversely, V-shaped or U-shaped contours pointing downhill toward lower elevations designate projecting ridges, spurs, and lateral moraines. Concentric closed loops denote mountain summits or isolated knolls, while closed contours containing internal hachure tick marks depict depressed sinkholes, volcanic craters, or kettle depressions.
Mastering terrain visualization allows navigators to practice proactive terrain modeling. By studying the contour spacing along an intended route corridor, a navigator identifies impassable obstacles (such as sheer cliff bands or uncrossable river canyons) hours before arriving at them, selecting natural contour benches, gentle spur shoulders, and safe col crossing passes that minimize physical energy expenditure and avoid high-hazard alpine terrain.
Magnetic Declination Physics and Compass Grid Calibration
Operating a magnetic compass requires an understanding of terrestrial geomagnetism. The planet possesses two distinct northern geographic poles: True North (the geographic North Pole, representing the northern axis of planetary rotation) and Magnetic North (the dynamic location in northern Canada and the Arctic Ocean where the Earth’s geomagnetic field lines point vertically into the earth’s core).
The horizontal angular difference between True North and Magnetic North from any specific geographic vantage point is termed magnetic declination. In western North America, magnetic declination is easterly (the compass needle points to the east of true north); in eastern North America, declination is westerly. Furthermore, topographic maps incorporate a third reference direction: Grid North, representing the parallel vertical lines of the UTM grid projection. The angular deviation between Grid North and Magnetic North is the G-M (Grid-to-Magnetic) angle printed in the bottom marginal diagram of every standard quadrangle.
Failing to mathematically adjust for magnetic declination produces catastrophic navigational drift. In regions with a sixteen-degree easterly declination (such as the Pacific Northwest of the United States), following an uncorrected magnetic bearing of thirty degrees will cause a mountaineer to drift 280 meters off course for every single kilometer traveled. Over a five-kilometer traverse across a featureless snowfield, this uncorrected error lands the traveler more than 1.4 kilometers off target, potentially walking off a corniced cliff edge or missing a vital mountain pass completely.
Professional mountaineering compasses (such as the Silva Expedition or Suunto MC-2 mirror compass) feature mechanical declination adjustment screws located on the underside of the rotating compass bezel. By turning the miniature brass screw with a dedicated key, the navigator shifts the internal orienting arrow by the exact declination angle printed on the map. Once calibrated, the compass automatically translates between map grid bearings and field magnetic bearings, completely eliminating the cognitive burden of mental addition or subtraction under freezing, hypothermic field conditions.
Resection, Intersection, and Triangulation Position Fixing
When traveling through unfamiliar alpine wilderness, a navigator must be capable of establishing an exact geographic position on the paper map using resection geometry. Resection is the mathematical process of locating one’s unknown position by taking compass bearings to two or more prominent, visually identifiable distant landmarks whose exact locations are mapped on the quadrangle.
To execute a resection, the navigator identifies a prominent distant landmark (such as an isolated mountain peak, a sheer rock buttress, or an island in a mountain lake) and sights through the compass sighting mirror, aligning the hairline with the landmark. The compass bezel is rotated until the magnetic needle sits perfectly inside the orienting arrow (“the needle in the shed”), recording the precise magnetic bearing. The reciprocal back-bearing is calculated (adding 180 degrees if the bearing is under 180, or subtracting 180 degrees if over 180).
The compass baseplate edge is placed against the mapped landmark on the quadrangle, rotating the entire compass until the internal orienting lines parallel the map’s north-south grid lines. A fine line of position (LOP) is drawn backward from the landmark across the map. The navigator then repeats this process on a second landmark situated roughly sixty to ninety degrees away from the first. The point where the two lines of position intersect represents the navigator’s exact location on the terrain.
Taking a third bearing to a third distant landmark provides a definitive error-checking triangulation fix. Because minor sighting errors are inevitable in rugged terrain, three intersecting lines of position rarely converge at a single infinitesimal point; instead, they form a small triangle known as the “triangle of error.” If the triangle of error is small (measuring a few millimeters across on the map), the navigator’s true position is located within the center of the triangle, providing an unshakeable spatial fix independent of satellite electronics.
Dead Reckoning Mechanics: Pace Counting and Time-Distance Ratios
When severe weather obliterates all visual landmarks, reducing visibility to less than five meters during dense mountain fog or blizzard whiteouts, resection becomes impossible. In these blinding conditions, the navigator must rely on dead reckoning (deduced reckoning), navigating forward from the last known geographic fix using compass bearings, measured pacing counts, and calibrated travel elapsed time.
Pace counting is the physical measurement of distance traveled based on individual walking strides. A pace is defined as two natural steps (counted every time the left foot strikes the ground). Navigators calibrate their personal pace count over a measured one-hundred-meter baseline marked across varying terrain types: flat packed trail, steep uphill talus, deep loose snow, and dense boulder fields. While an average adult male takes approximately sixty to sixty-five paces per hundred meters on flat ground, steep uphill climbs elevate the count to eighty-five to ninety-five paces, while post-holing through knee-deep snow can push counts above 110 paces per hundred meters.
To record pace counts without losing track during prolonged marches, mountaineers use ranger pace beads (bead cords attached to pack straps) consisting of nine lower beads representing one-hundred-meter intervals and four upper beads representing one-kilometer increments. Every time the navigator completes one hundred meters of counted paces, one lower bead is slid downward. When all nine lower beads are down and the next hundred meters is completed, one upper kilometer bead is pulled down, providing an unshakeable, mechanical record of total distance covered.
Time-distance modeling utilizing Naismith’s Rule provides an additional mathematical layer of dead reckoning verification. Formulated by Scottish mountaineer William Naismith, the baseline rule establishes that an adult hiker walks at a speed of five kilometers per hour on flat terrain, adding thirty minutes of elapsed time for every three hundred meters of vertical elevation gained. Adjusting Naismith’s Rule for heavy expedition packs (reducing flat speed to four km/h) enables navigators to calculate precise estimated times of arrival (ETA) for each navigational waypoint along the route.
Barometric Altimetry Calibration and Isobaric Elevation Tracking
In rugged alpine topography where vertical relief dominates horizontal distance, an accurate analog or barometric altimeter represents the single most valuable navigational instrument in an expedition leader’s kit. A barometric altimeter measures ambient atmospheric pressure, translating the predictable drop in barometric pressure that occurs with ascending altitude into vertical elevation above sea level.
In mountainous terrain, knowing one’s exact vertical elevation instantly provides an unambiguous line of position across a topographic map. If an altimeter registers an elevation of exactly 2,800 meters, the navigator knows with absolute certainty that they are located somewhere along the mapped 2,800-meter contour line. When combined with a single compass bearing to a distant river valley, or by following a distinct geological ridge line, the intersection of the altimeter elevation line with the terrain feature generates an instantaneous, highly accurate two-point position fix.
However, barometric altimeters are vulnerable to atmospheric pressure shifts caused by changing regional weather fronts. A sudden drop in regional barometric pressure caused by an approaching low-pressure storm front will cause an unadjusted altimeter to register an apparent elevation increase of fifty to one hundred meters even while the expedition remains stationary in camp. Navigators must continuously recalibrate their altimeters at every known geographic landmark (such as lake shores, surveyed mountain passes, or marked trail junctions) where the true elevation is printed on the quadrangle.
Furthermore, tracking barometric altimeter drift while stationary provides an infallible early-warning weather forecasting tool. If the altimeter indicates a steady climb in elevation overnight while the camp remains fixed at the same physical location, it signals a rapidly plunging atmospheric pressure front, warning the expedition that a severe cyclonic storm or blizzard will strike the mountain within twelve to twenty-four hours, allowing the team to fortify camp or initiate descent before whiteout conditions trap them on exposed ridges.
Aiming Off, Catch Features, and Attack Points in Route Finding
A classic navigational mistake made by inexperienced wilderness travelers is attempting to navigate directly toward a small, discrete target (such as a hidden backcountry shelter, a narrow bridge crossing, or a tiny alpine tarn) over long distances using a straight compass bearing. Due to inevitable lateral drift caused by uneven terrain, wind gusts, and dodging obstacles, the navigator almost invariably drifts slightly to the left or right of the target. Upon arriving at the target distance, the traveler has no idea whether the target lies fifty meters to their left or fifty meters to their right, leading to frantic searching and panic.
Professional navigators employ the strategic technique of “aiming off.” Instead of aiming directly at the small target, the navigator deliberately aims several degrees to a specific, pre-determined side of the target (e.g., aiming two hundred meters to the left of the footbridge along an intersecting river). When the navigator reaches the linear feature (the river), they know with mathematical certainty that the target lies to their right. They simply turn ninety degrees right and walk along the riverbank until the footbridge appears.
Catch features (backstops) represent prominent, unmistakable linear terrain features located immediately behind the intended target. A catch feature can be a roaring mountain river, a towering vertical cliff face, a distinct high-elevation ridge line, or an old logging road. Navigators select a catch feature to prevent catastrophic overshoot: if the expedition walks beyond the target without spotting it, hitting the catch feature immediately alerts the team that they have traveled too far, arresting further dangerous wandering and initiating a structured back-track protocol.
Attack points represent easily identifiable, prominent terrain features located close to the final obscure destination. Navigators move rapidly and aggressively across the landscape toward the large attack point (such as a prominent alpine lake or a distinct rocky knoll). Once established at the attack point, the team pauses, recalculates a precise, short-distance dead reckoning bearing and pace count, and executes the final technical approach with maximum spatial precision.
Glacial Crevasse Field Navigation and Micro-Relief Morphology
Navigating glaciated alpine terrain without satellite navigation represents the ultimate test of topographic and glaciological literacy. Glaciers are dynamic, flowing rivers of ice whose surface crevasse patterns are governed by underlying bedrock topography and stress mechanics. Longitudinal crevasses form parallel to ice flow where the glacier widens; transverse crevasses open perpendicular to flow where the glacier steepens over subglacial bedrock steps; and marginal crevasses angle upstream along valley sidewalls due to friction with lateral moraines.
When crossing heavily crevassed glaciers in flat light or dense cloud cover, navigators identify hidden crevasse fields through subtle micro-relief changes in the surface snowpack. Early morning low-angle solar shadows or faint concave depressions in the snow surface reveal sagging snow bridges spanning subterranean chasms. Navigators maintain rope-team discipline, traveling perpendicular to the primary crevasse alignment to ensure that if a lead climber breaches a hidden snow bridge, the following team members remain positioned on solid ice to arrest the fall.
Dead reckoning across expansive, featureless glacial plateaus requires pairing compass bearings with wands (bamboo stakes fitted with high-visibility orange survey flags). As the lead climber marches forward on the compass bearing, the team plants wands into the snowpack every fifty to one hundred meters. Looking backward along the line of planted wands provides an instantaneous visual back-bearing, allowing the team to correct for lateral wind drift and maintain a perfectly straight course through zero-visibility whiteouts.
Night Navigation and Low-Visibility Auditory Terrain Tracking
When expeditions are forced to navigate through dense alpine forests or steep talus passes under nocturnal darkness, visual cues degrade dramatically. Standard headlamp beams illuminate only five to ten meters ahead, reflecting off airborne fog droplets and creating an optical glare that blinds the traveler to distant horizon contours. In nocturnal environments, sensory navigation must expand to incorporate auditory, tactile, and microclimatic feedback.
Auditory terrain association relies on acoustic sound reflection and hydrographic tracking. The distinct roar of an alpine river or cascading waterfall provides an unmistakable acoustic beacon that navigators triangulate against contour lines. In dense timber, sound echoes differently off sheer rock faces compared to open meadows: a mountaineer shouting into the fog can gauge the proximity of towering headwalls by listening to acoustic echo delay times (sound travels approximately 343 meters per second; a one-second return echo indicates a rock barrier 170 meters away).
Tactile underfoot feedback provides critical slope information. Navigators sense the subtle transition from firm glacial moraine gravel into loose talus scree, or detect the transition from dry, porous alpine turf into saturated sphagnum moss bogs. Furthermore, nocturnal mountain winds follow predictable katabatic drainage flow: cold, dense air flows downhill through mountain ravines at night. Feeling the cold katabatic breeze on one’s face or neck provides an immediate verification of slope direction, keeping the traveler oriented even when visual sightlines are completely extinguished.
Celestial Navigation Mechanics: Sun Shadows, Stars, and Moon Phases
When compass hardware is lost, damaged, or subjected to intense local magnetic interference (such as traversing iron-rich basalt rock formations or high-voltage transmission corridors), celestial bodies provide an unshakeable, global orientation framework. The sun, moon, and stellar constellations operate on immutable celestial mechanics that allow an observant navigator to establish cardinal directions with remarkable accuracy.
The shadow-stick method provides an infallible daytime solar orientation technique. The navigator drives a straight, one-meter wooden stick vertically into level, bare ground and places a small stone at the tip of the cast shadow. The team waits fifteen to twenty minutes while the sun moves across the sky, and places a second stone at the new tip of the elongated shadow. A straight line drawn from the first stone to the second stone represents an exact west-to-east line: the first stone is always West, and the second stone is always East. Standing with the first stone on one’s left and the second stone on one’s right aligns the navigator facing True North.
Analog watch navigation offers a rapid solar bearing check in temperate zones. In the Northern Hemisphere, holding an analog watch horizontal and pointing the hour hand directly toward the sun establishes an angular baseline; the line that bisects the angle between the hour hand and the twelve o’clock mark points directly toward True South. In the Southern Hemisphere, pointing the twelve o’clock mark toward the sun means that the line bisecting the twelve o’clock mark and the hour hand points directly toward True North.
At night in the Northern Hemisphere, locating Polaris (the North Star) provides True North within one degree of azimuth. Polaris is located by identifying the Big Dipper (Ursa Major) and sighting along the two outer “pointer stars” of the dipper bowl (Merak and Dubhe). Extending an imaginary line through the pointer stars five times their distance leads directly to Polaris, which marks the tip of the handle of the Little Dipper (Ursa Minor). In the Southern Hemisphere, the Southern Cross (Crux) and pointer stars Alpha and Beta Centauri are used to project an imaginary line downward to establish True South.
Avalanche Terrain Hazard Analysis and Slope Incline Cartography
In winter and spring alpine exploration, navigation and avalanche hazard mitigation are inextricably linked. Snow avalanches do not occur randomly across the landscape; the vast majority of lethal slab avalanches release on slope inclines between thirty and forty-five degrees, with the highest hazard frequency concentrated precisely on thirty-eight-degree slopes.
Navigators must evaluate slope incline directly from the topographic map prior to selecting route corridors. Slope steepness is calculated by dividing the vertical elevation gain (rise) by the horizontal ground distance (run) measured from the quadrangle using a clear plastic map scale. Converting the slope gradient into degrees: Incline = arctan(Rise / Run). Many professional orienteering compasses feature printed slope scale rulers along their baseplate edges that allow navigators to measure contour line spacing directly, instantly identifying hazardous slopes exceeding thirty degrees.
Furthermore, cartographic route planning must identify terrain traps. Terrain traps are landscape depressions, gullies, crevasse fields, and creek beds located beneath avalanche slopes where even a small, harmless snow slide can accumulate into tens of meters of deeply buried, suffocating debris. Navigators plan high-angle routes along broad, rounded ridge crests and wind-scoured shoulders that shed snow naturally, avoiding leeward convex rolls, corniced ridge lines, and confined gully bottoms.
In the field, mountaineers verify cartographic slope calculations using mechanical inclinometers (clinometers) built into professional sighting compasses. Sighting up or down the slope through the compass mirror and reading the internal pendulum clinometer scale provides real-time verification of slope angles, allowing the team to alter route headings before entering active avalanche release zones.
Expedition Route Card Architecture and Contingency Protocol Design
Professional alpine expeditions never embark into remote wilderness without a formalized, written Route Card. A Route Card is a structured operational document that breaks the proposed expedition into distinct, measurable navigational legs, detailing magnetic bearings, grid coordinates, horizontal distances, vertical elevation profiles, estimated elapsed times, and designated hazard zones for every segment of the journey.
For every navigational leg, the Route Card records the primary bearing, reciprocal back-bearing, prominent catch features, designated attack points, and specific decision points (escape routes). Decision points are pre-determined geographic coordinates where the expedition leader pauses to evaluate team physical fatigue, current weather trends, and snowpack stability against strict objective turnaround times (drop-dead times), ensuring that the team retreats safely before nightfall or incoming storms trap them in exposed high-altitude terrain.
Contingency planning includes pre-mapping bad-weather bypass routes (foul-weather alternatives) that circumvent technical exposed ridges in favor of sheltered valley floors during whiteout conditions. Furthermore, emergency bailout bearings are calculated in advance: if a catastrophic injury or storm strikes, the team executes a single, pre-determined compass bearing that leads directly toward a major highway, ranger station, or established emergency shelter, eliminating confusion and panic during life-threatening crises.
To assist wilderness expedition leaders and mountain rescue personnel in evaluating navigational equipment and methodological trade-offs across distinct wilderness terrains, cartographic specialists utilize comprehensive comparative matrices. Analyzing operational parameters across modern satellite GPS, standalone smartphone apps, and traditional analog map-and-compass navigation provides an objective framework for expedition risk management.
The following comparative diagnostic matrix illustrates the structural, environmental, and operational characteristics governing each wilderness navigation framework.
Comparative Diagnostic Matrix of Wilderness Navigation Frameworks
| Navigational Parameter | Dedicated Satellite GPS Receiver | Smartphone Mapping Application | Analog Map, Compass & Altimeter |
|---|---|---|---|
| Power & Battery Independence | Poor (15 to 30 hours, rechargeable) | Critical (6 to 12 hours, rapid winter drain) | 100 percent infinite (zero electricity) |
| Sub-Zero Thermal Tolerance | Moderate (screen lag, cold battery drop) | Catastrophic (spontaneous shutdown at 0 C) | Flawless (-40 C liquid compass capsule) |
| Satellite Signal Attenuation Risk | Moderate (lost in deep slot canyons/cirques) | High (weak internal phone antennas) | Zero (operates via geomagnetic physics) |
| Physical Impact Durability | High (ruggedized rubberized chassis) | Fragile (glass screen shatters on rocks) | Extreme (waterproof polymer map & baseplate) |
| Spatial Context & Macro-Vision | Narrow (small 2.5-inch display screen) | Limited (requires zooming in/out) | Exhaustive (full 7.5-minute regional view) |
| Geomagnetic Interference Susceptibility | Low (relies on trilateration) | Medium (electronic internal magnetometer) | Moderate (deflects near iron basalt rocks) |
| Initial Positional Acquisition Speed | Instantaneous (push-button coordinates) | Instantaneous (when GPS locked) | Moderate (requires triangulation/pacing) |
| Technical Operator Skill Requirement | Low (basic button navigation) | Very Low (intuitive touchscreen UI) | High (demands rigorous training & practice) |
Authoritative wilderness navigation standards published by national cartographic institutions, including the United States Geological Survey National Geospatial Program and alpine safety manuals from the Mountaineers Freedom of the Hills Editorial Board, definitively affirm that analog map-and-compass literacy represents the non-negotiable prerequisite for alpine wilderness travel. Research teams at the Ordnance Survey Map Skills Academy publish rigorous cartographic training guidelines. Furthermore, terrestrial navigation studies indexed in the Journal of Environmental Management and spatial cognition analyses in Nature Scientific Reports Cognitive Science demonstrate that analog orienteering builds superior spatial situational awareness and situational hazard recognition compared to passive digital screen following. These institutional findings provide the rigorous scientific basis required to answer critical navigation questions across remote wilderness expeditions.
Frequently Asked Questions About Analog Wilderness Navigation
What is the difference between True North, Magnetic North, and Grid North?
True North represents the geographic North Pole on the Earth’s rotational axis. Magnetic North is the location where the Earth’s geomagnetic lines point into the ground, pulling magnetic compass needles toward northern Canada. Grid North represents the vertical lines of the UTM cartographic projection on a flat paper map. The angular difference between True North and Magnetic North is magnetic declination, which must be mathematically adjusted on compass bezels.
How does a barometric altimeter provide an instant line of position?
A barometric altimeter measures atmospheric pressure to determine vertical elevation above sea level. Because contour lines on a topographic map connect points of identical elevation, reading an exact elevation (e.g., 2,500 meters) places the navigator somewhere along that specific mapped 2,500-meter contour line, creating an instant topographic line of position.
What is the navigational strategy of aiming off and when is it utilized?
Aiming off involves deliberately aiming a compass bearing slightly to one side of a small target feature (such as an emergency footbridge along a river) rather than directly at it. When the traveler reaches the linear catch feature (the riverbank), they know with certainty that the bridge lies in the opposite direction of the deliberate offset, eliminating confusion over whether to turn left or right.
How do pace beads work to measure wilderness travel distance?
Pace beads (ranger beads) measure distance based on counted paces (two natural steps). A hiker counts paces over one hundred meters (typically 60 to 70 paces on flat ground); upon completing one hundred meters, one lower bead is slid down. Sliding nine lower beads and completing the tenth hundred meters triggers pulling down one upper kilometer bead, mechanically tracking total kilometers covered without error.
Why do lithium batteries in GPS units and smartphones fail rapidly in alpine cold?
Lithium-ion battery chemistry relies on the movement of lithium ions through liquid electrolyte solutions. In freezing temperatures, the internal chemical reaction slows, internal electrical resistance escalates, and usable voltage drops precipitously, causing electronic receivers and phones to report sudden battery drainage and spontaneous shutdown even when ninety percent charged.
How is resection executed to find an unknown position on a map?
Resection is executed by taking compass bearings to two or more prominent, visually identifiable distant landmarks mapped on the quadrangle. Sighting bearings are converted to back-bearings and drawn as lines of position on the map backward from the landmarks. The intersection point of the lines of position establishes the navigator’s exact location.
What slope angles represent the highest danger for triggering slab avalanches?
The vast majority of fatal slab avalanches release on slope inclines between thirty and forty-five degrees, with peak avalanche hazard occurring on thirty-eight-degree slopes. Navigators calculate slope angles directly from contour line spacing on topographic maps, routing expeditions along broad ridge tops and slopes under twenty-five degrees to avoid hazard zones.
How does the shadow-stick method determine cardinal directions without a compass?
A straight stick is driven vertically into level ground, and the tip of the cast shadow is marked with a stone. After waiting fifteen to twenty minutes for the sun to move, a second stone is placed at the new shadow tip. A straight line connecting the first stone to the second stone forms an exact West-to-East line, allowing the traveler to determine True North.
What are catch features and why are they critical in whiteout navigation?
Catch features (backstops) are prominent, unmistakable linear terrain features (such as a roaring river, a vertical cliff band, or a high ridge line) located behind an intended waypoint. If the expedition misses the target in dense fog or whiteouts, striking the catch feature halts further wandering and confirms that the team has traveled past the destination.
Furthermore, advanced alpine orienteering incorporates micro-meteorological barometric trending. By pairing altimeter readings with continuous wind direction shifts and cloud veil evolution (such as observing high-altitude cirrus clouds feathering into altostratus), experienced mountain navigators anticipate violent cold frontal passages hours before squall lines strike, allowing expeditions to abort high-ridge traverses and seek secure bivouac shelter with ample safety margin.
Ultimately, analog alpine navigation is a profound testament to human intellectual sovereignty. When wilderness explorers leave behind digital reliance and master the timeless physical sciences of geomagnetism, cartography, altimetry, and spatial dead reckoning, they transform potentially lethal mountain terrain into an open, exhilarating landscape of purposeful discovery and enduring human achievement.
Orienteering Synthesis and the Enduring Mastery of Terrestrial Navigation
Analog alpine navigation is far more than a contingency backup for failed electronic gadgets; it is the ultimate expression of human self-reliance, spatial literacy, and environmental communion in wild places. By freeing oneself from the fragile umbilical cord of satellite screens and mastering the ancient geometry of magnetic compasses, contour interpretation, barometric altimetry, and dead reckoning, the wilderness explorer regains true agency. In an increasingly digitized, synthetic world, the ability to stand atop a remote, storm-swept mountain ridge, read the living topography of the earth, and navigate safely home under human power remains one of the most noble, empowering, and life-saving disciplines in exploration history.